[ Research Report — Embodied AI & Robotics ]
EAMS Autonomous Rover
Engineering Autonomous Mobility System
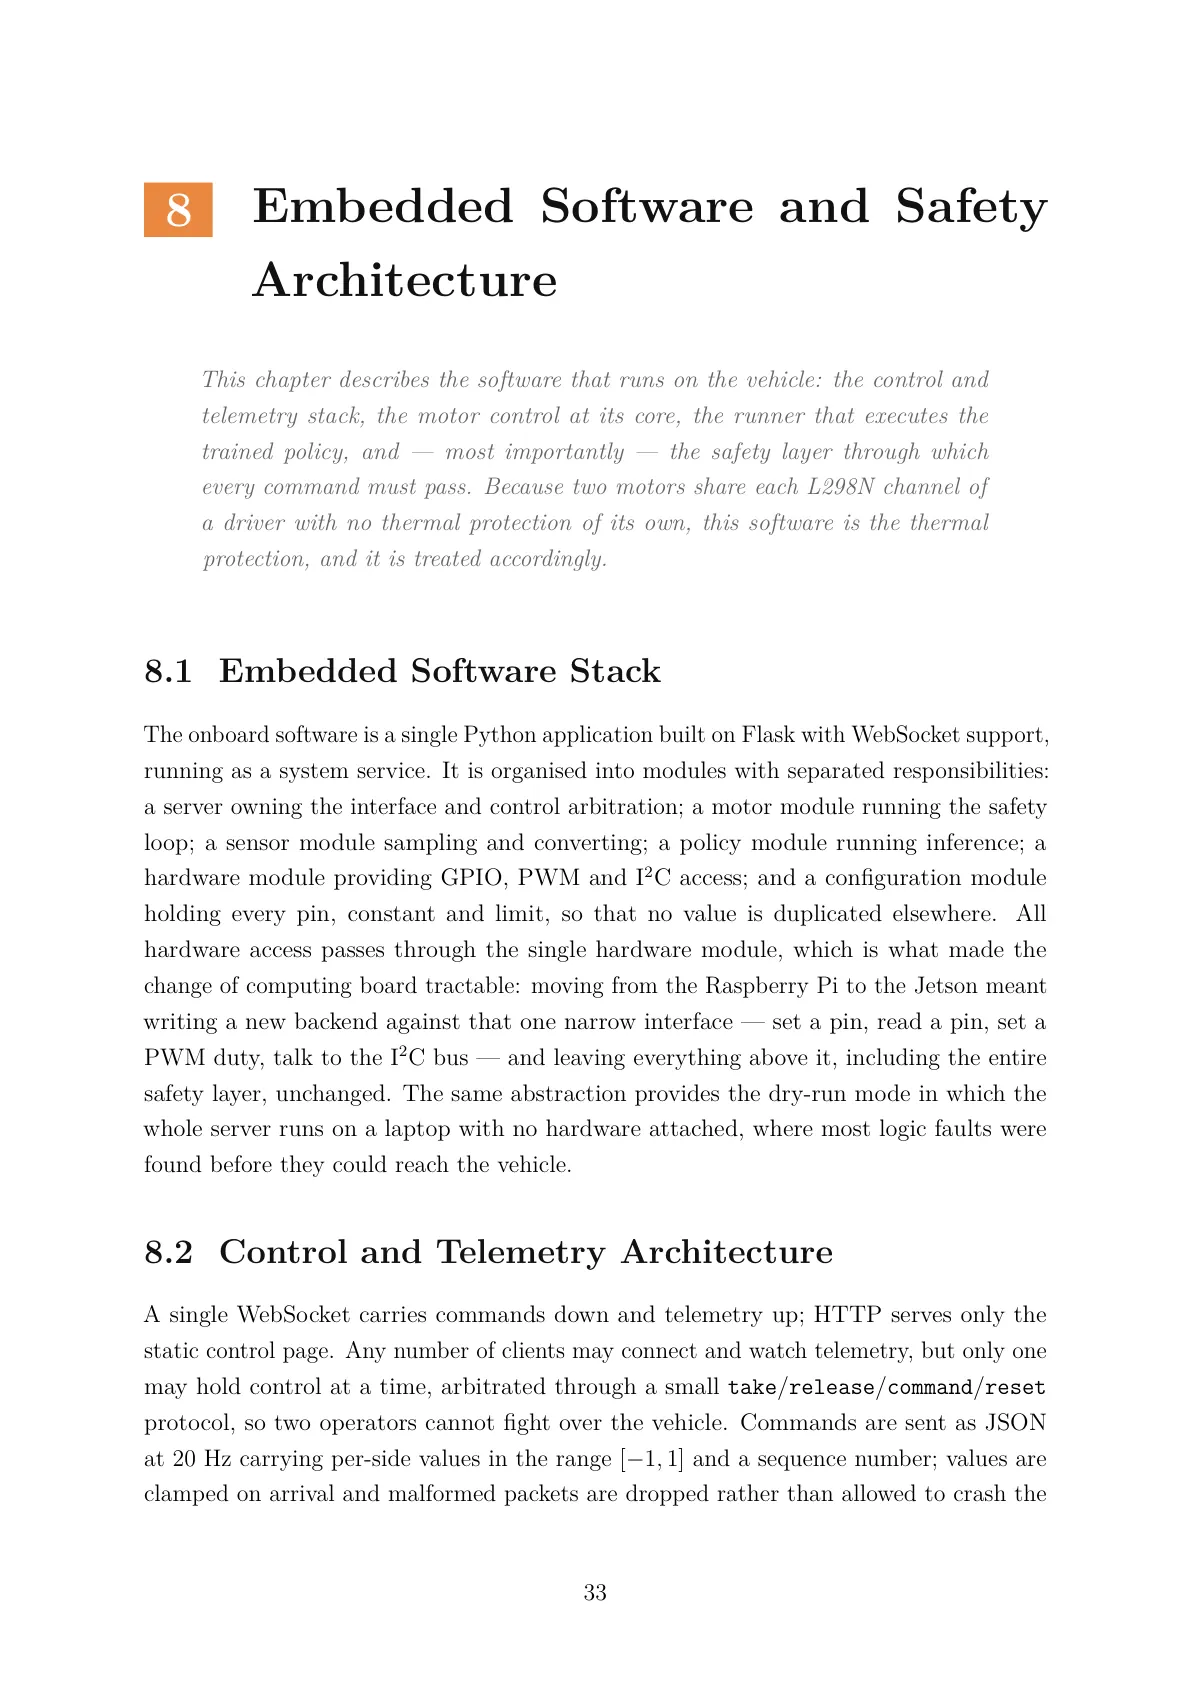
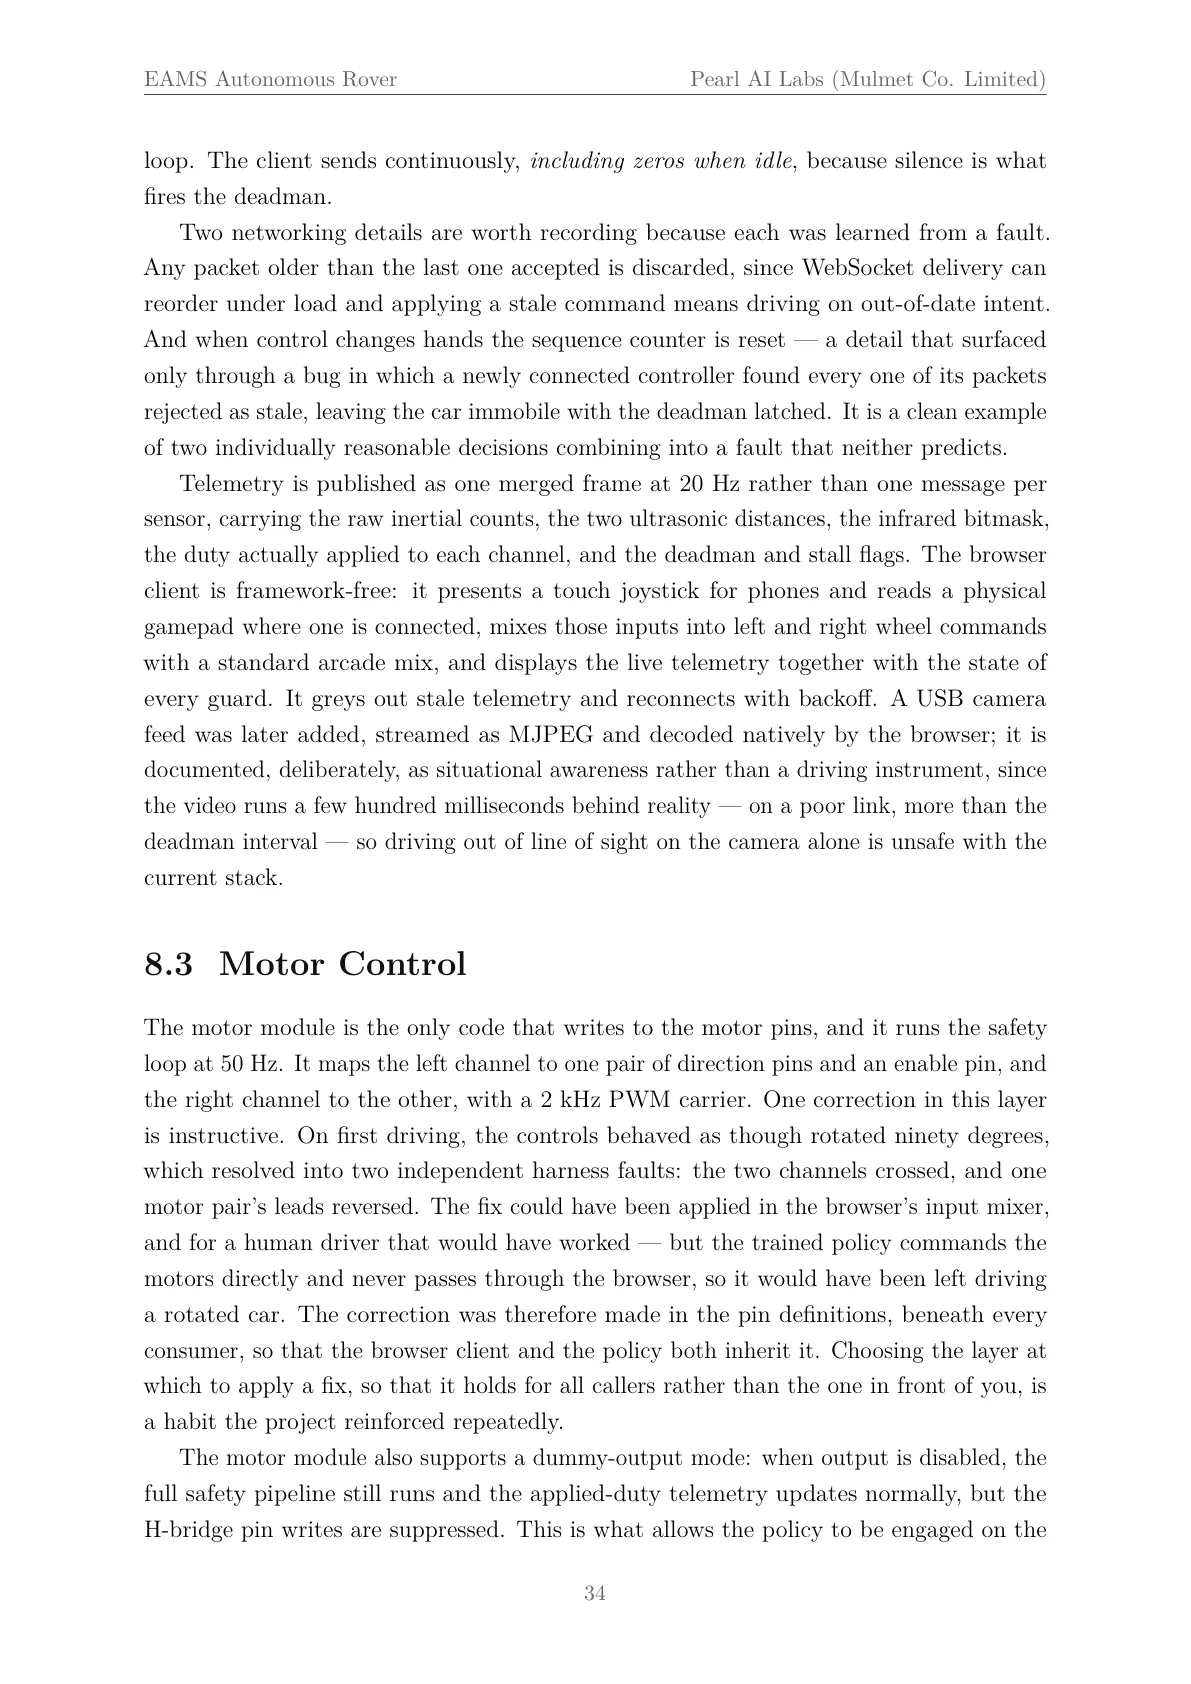
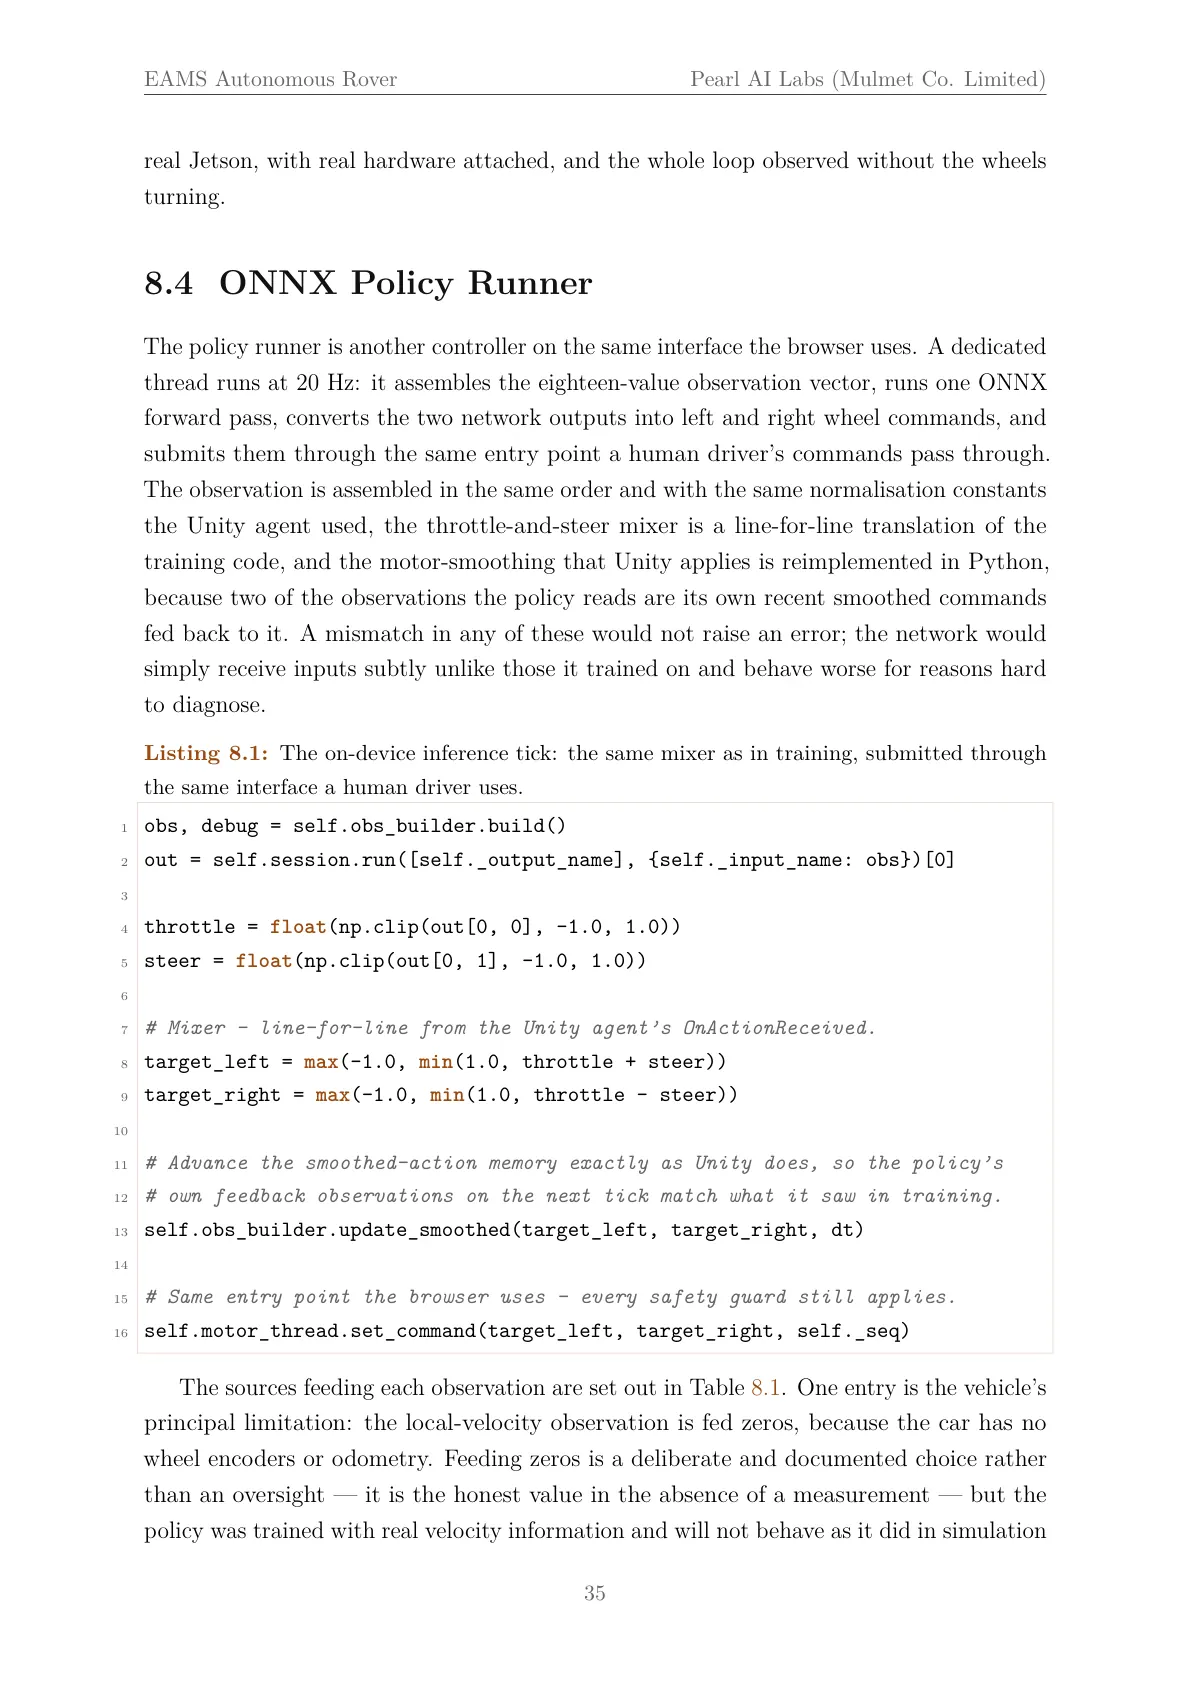
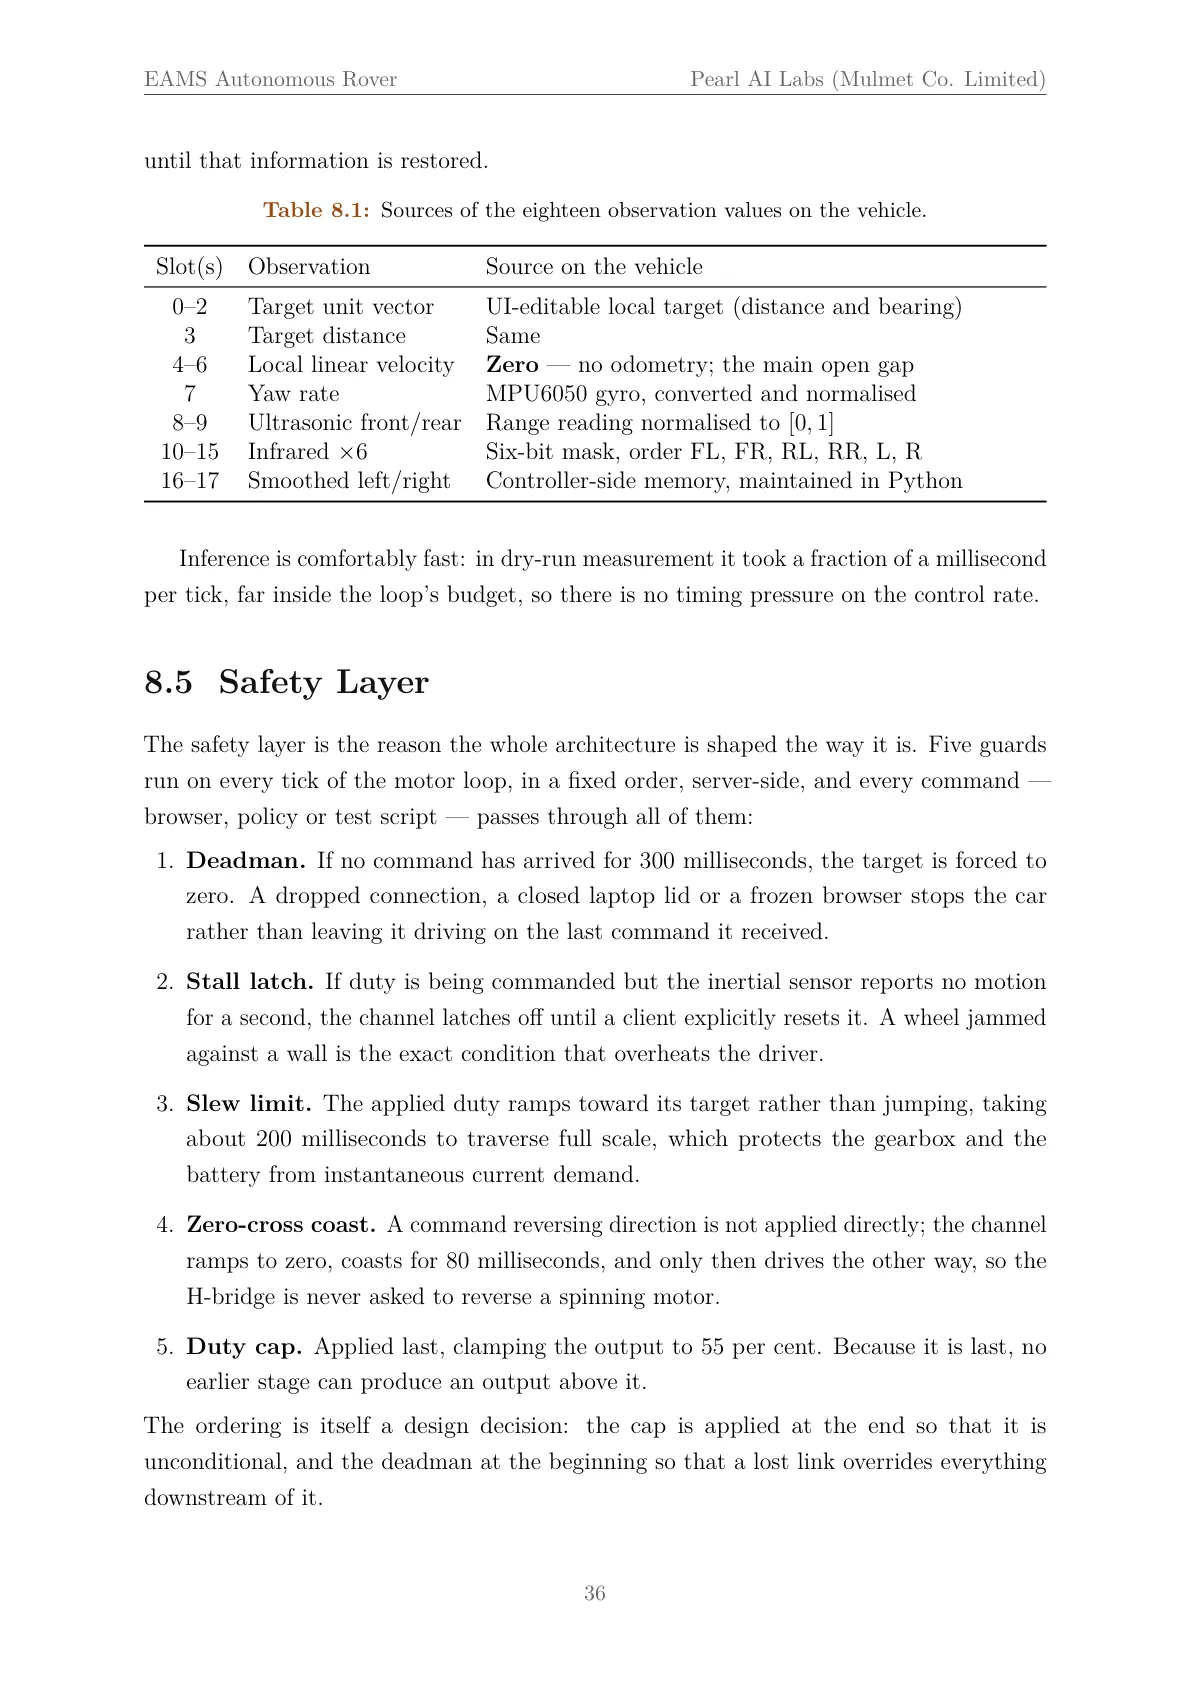
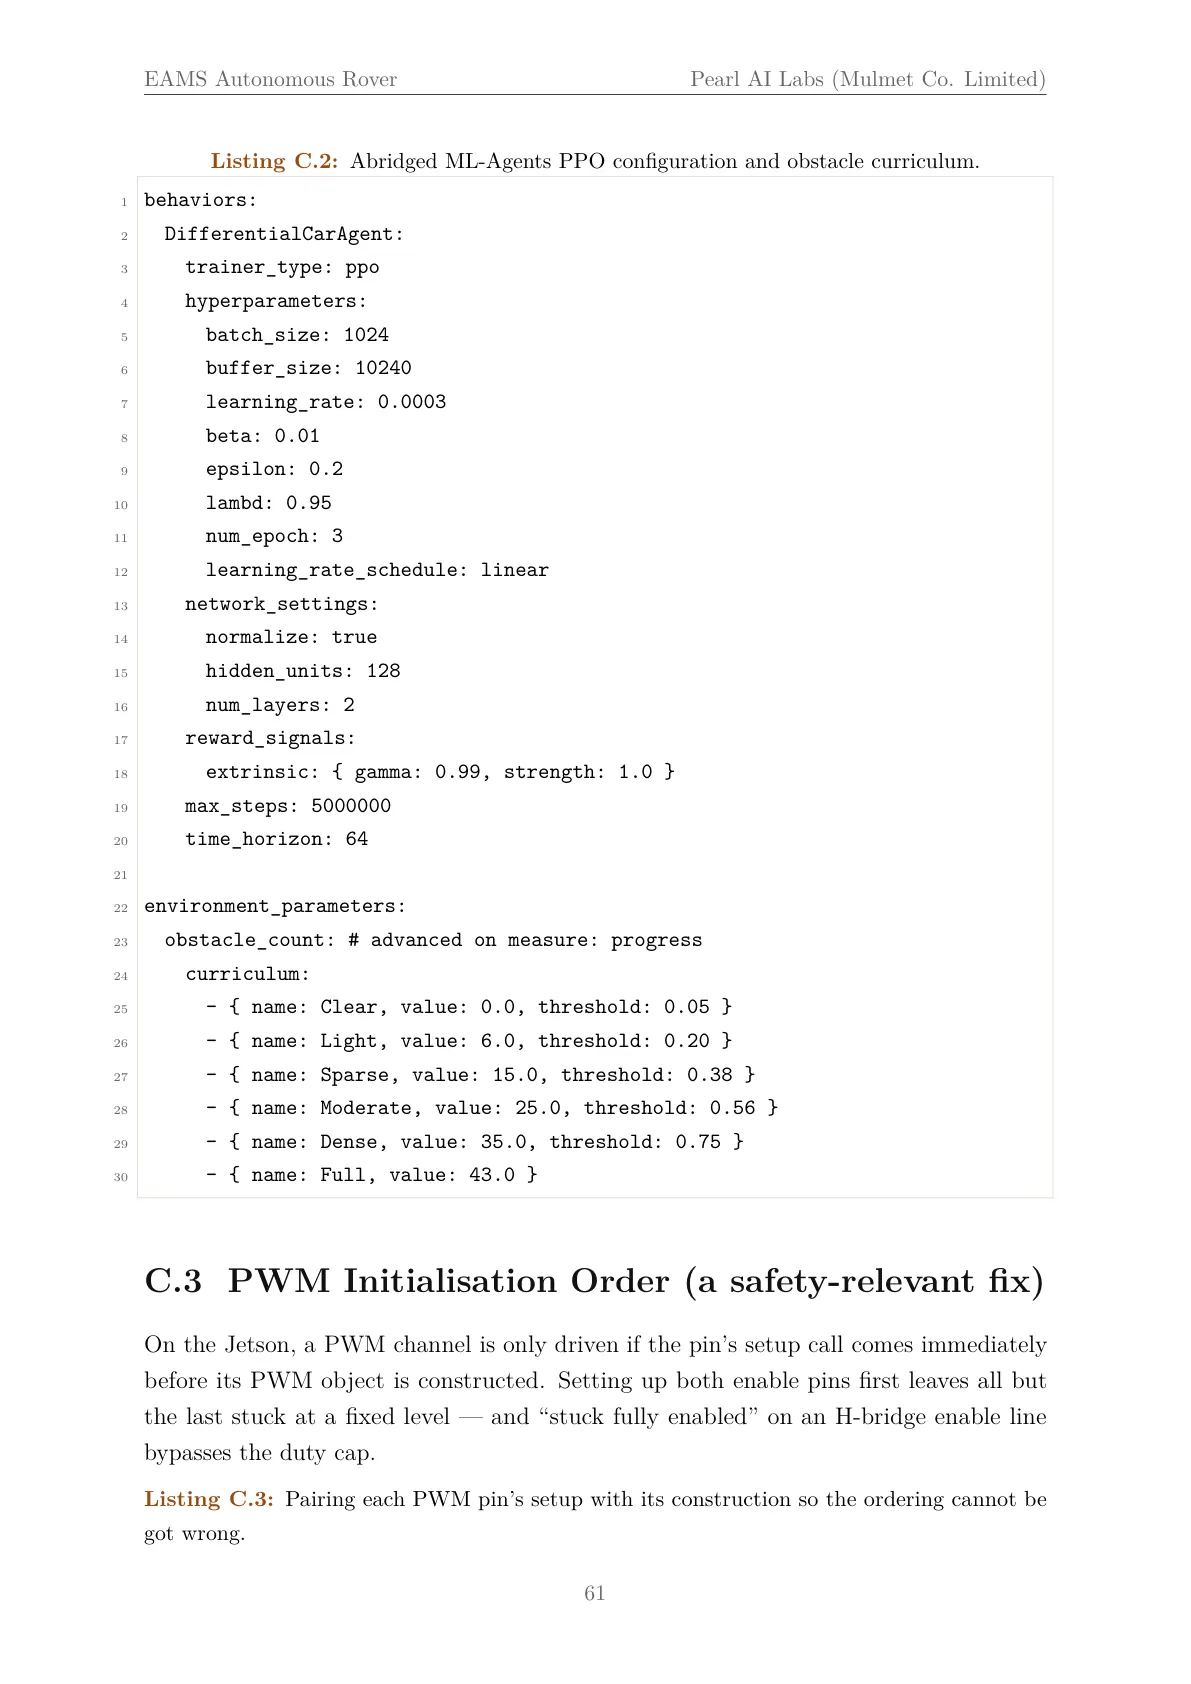
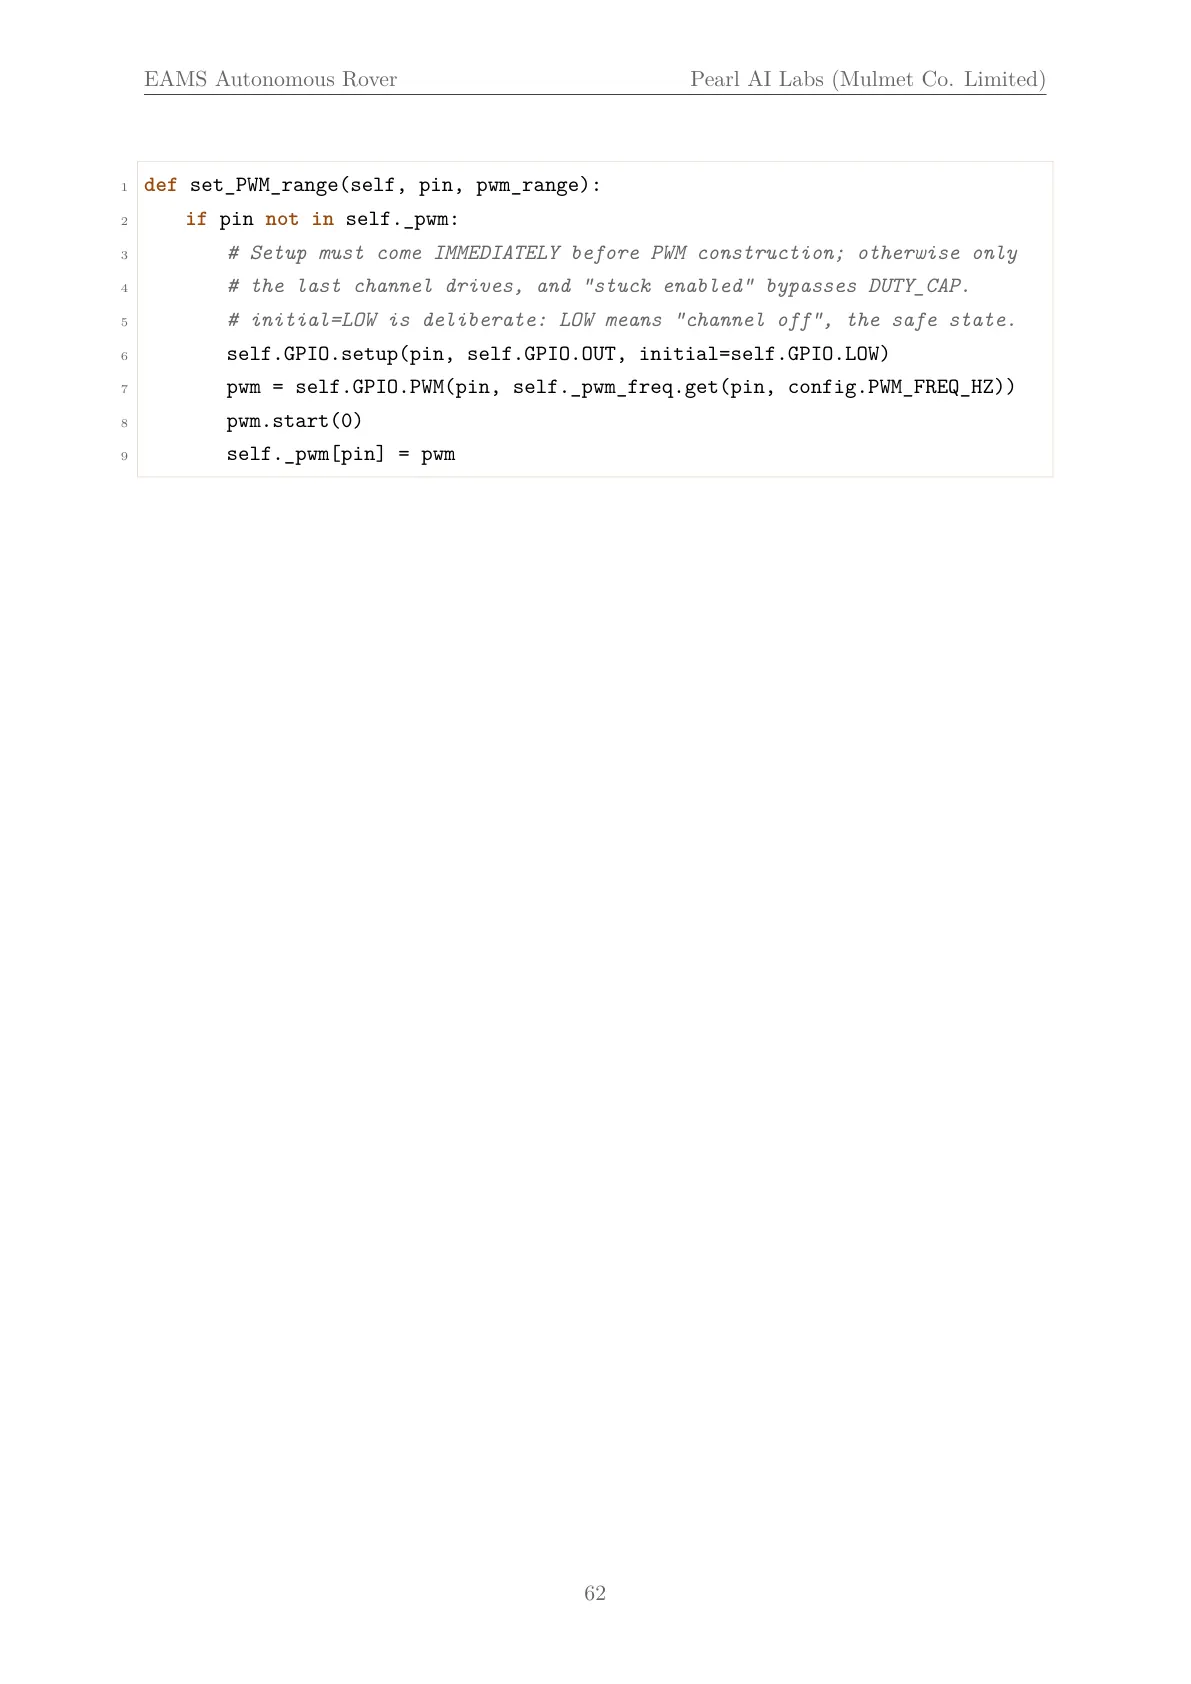
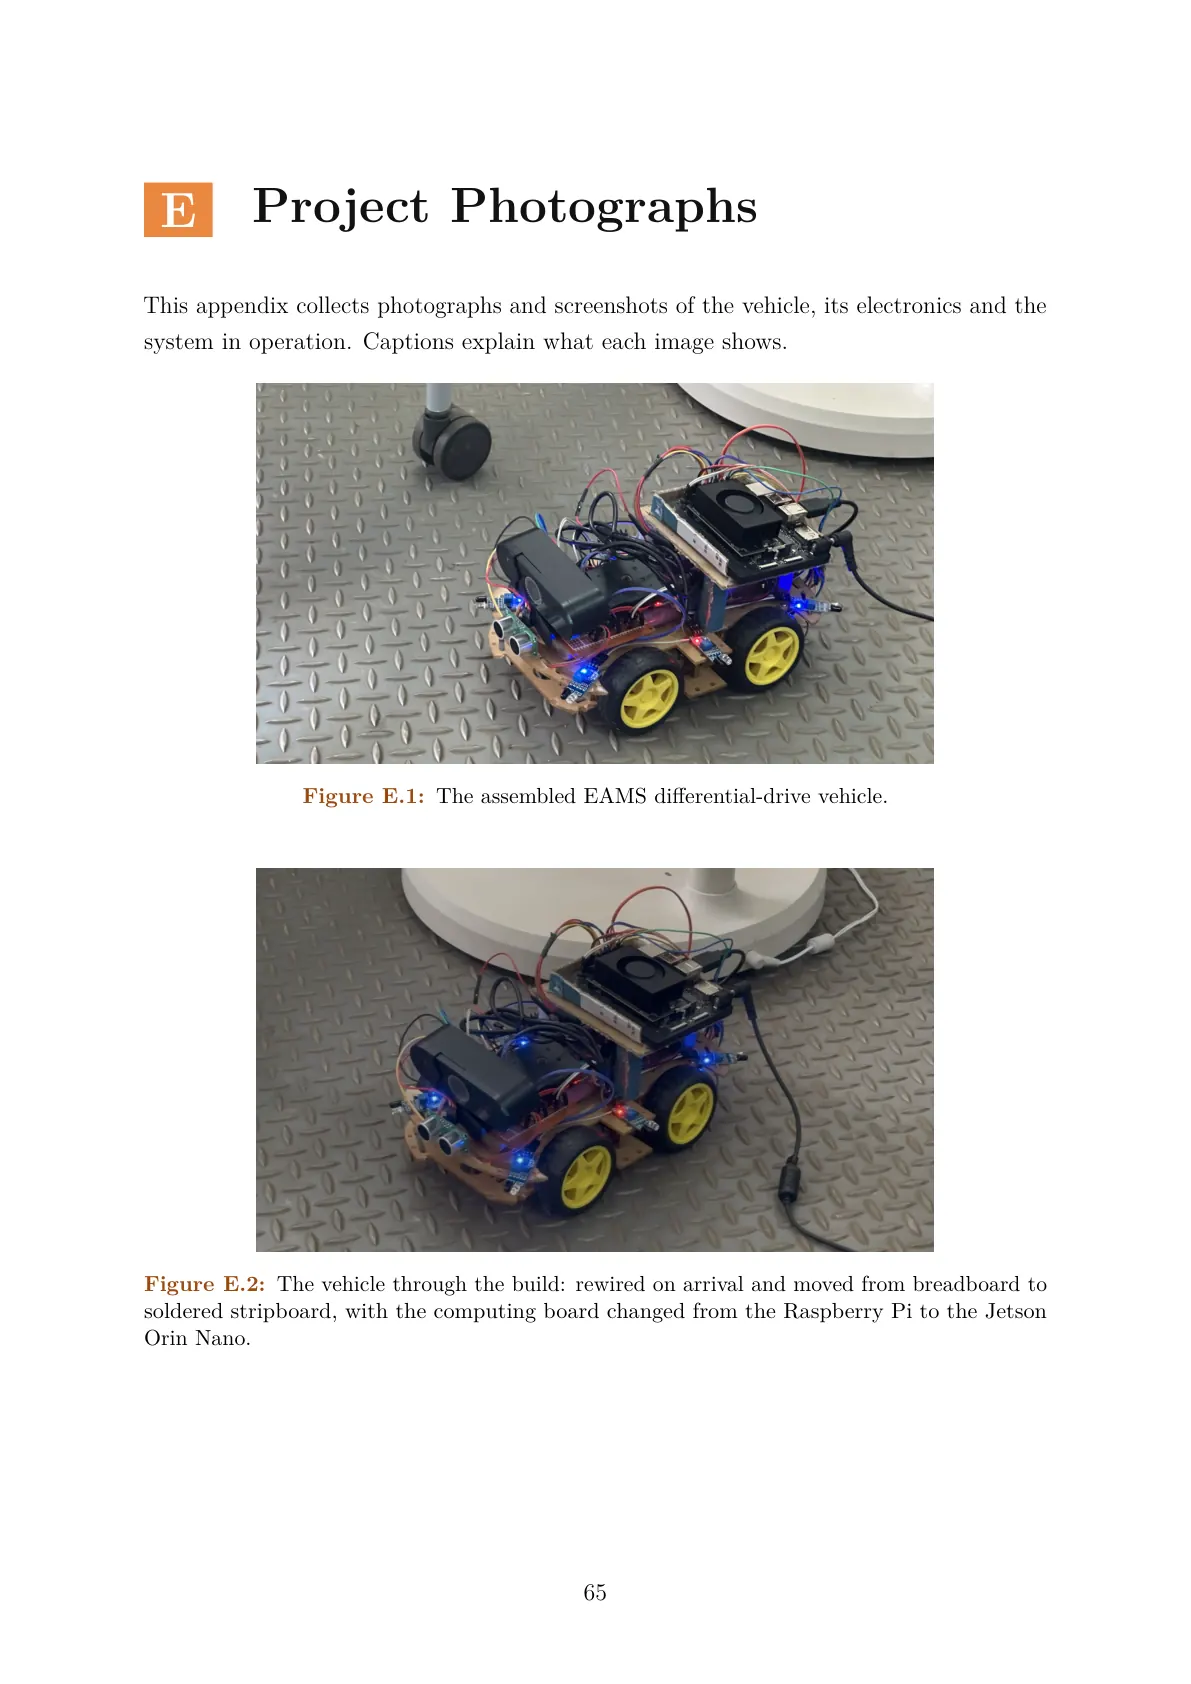
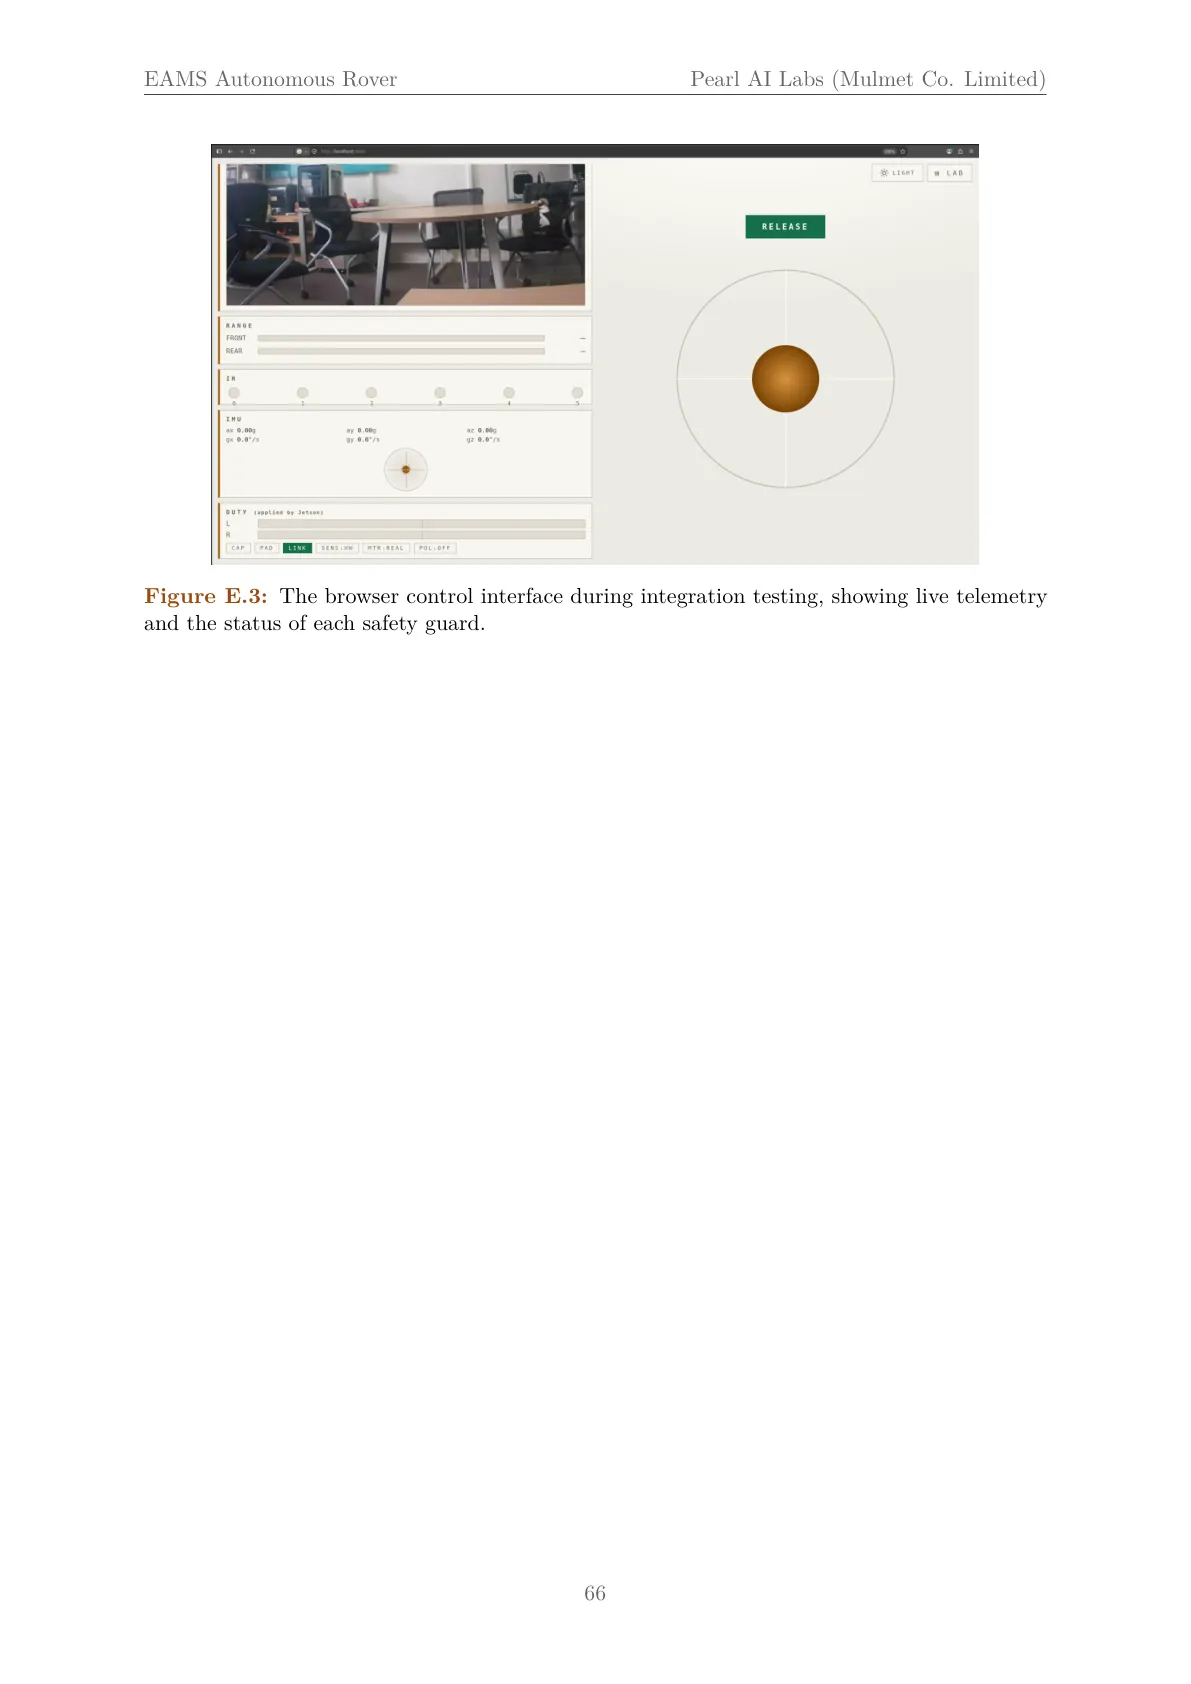
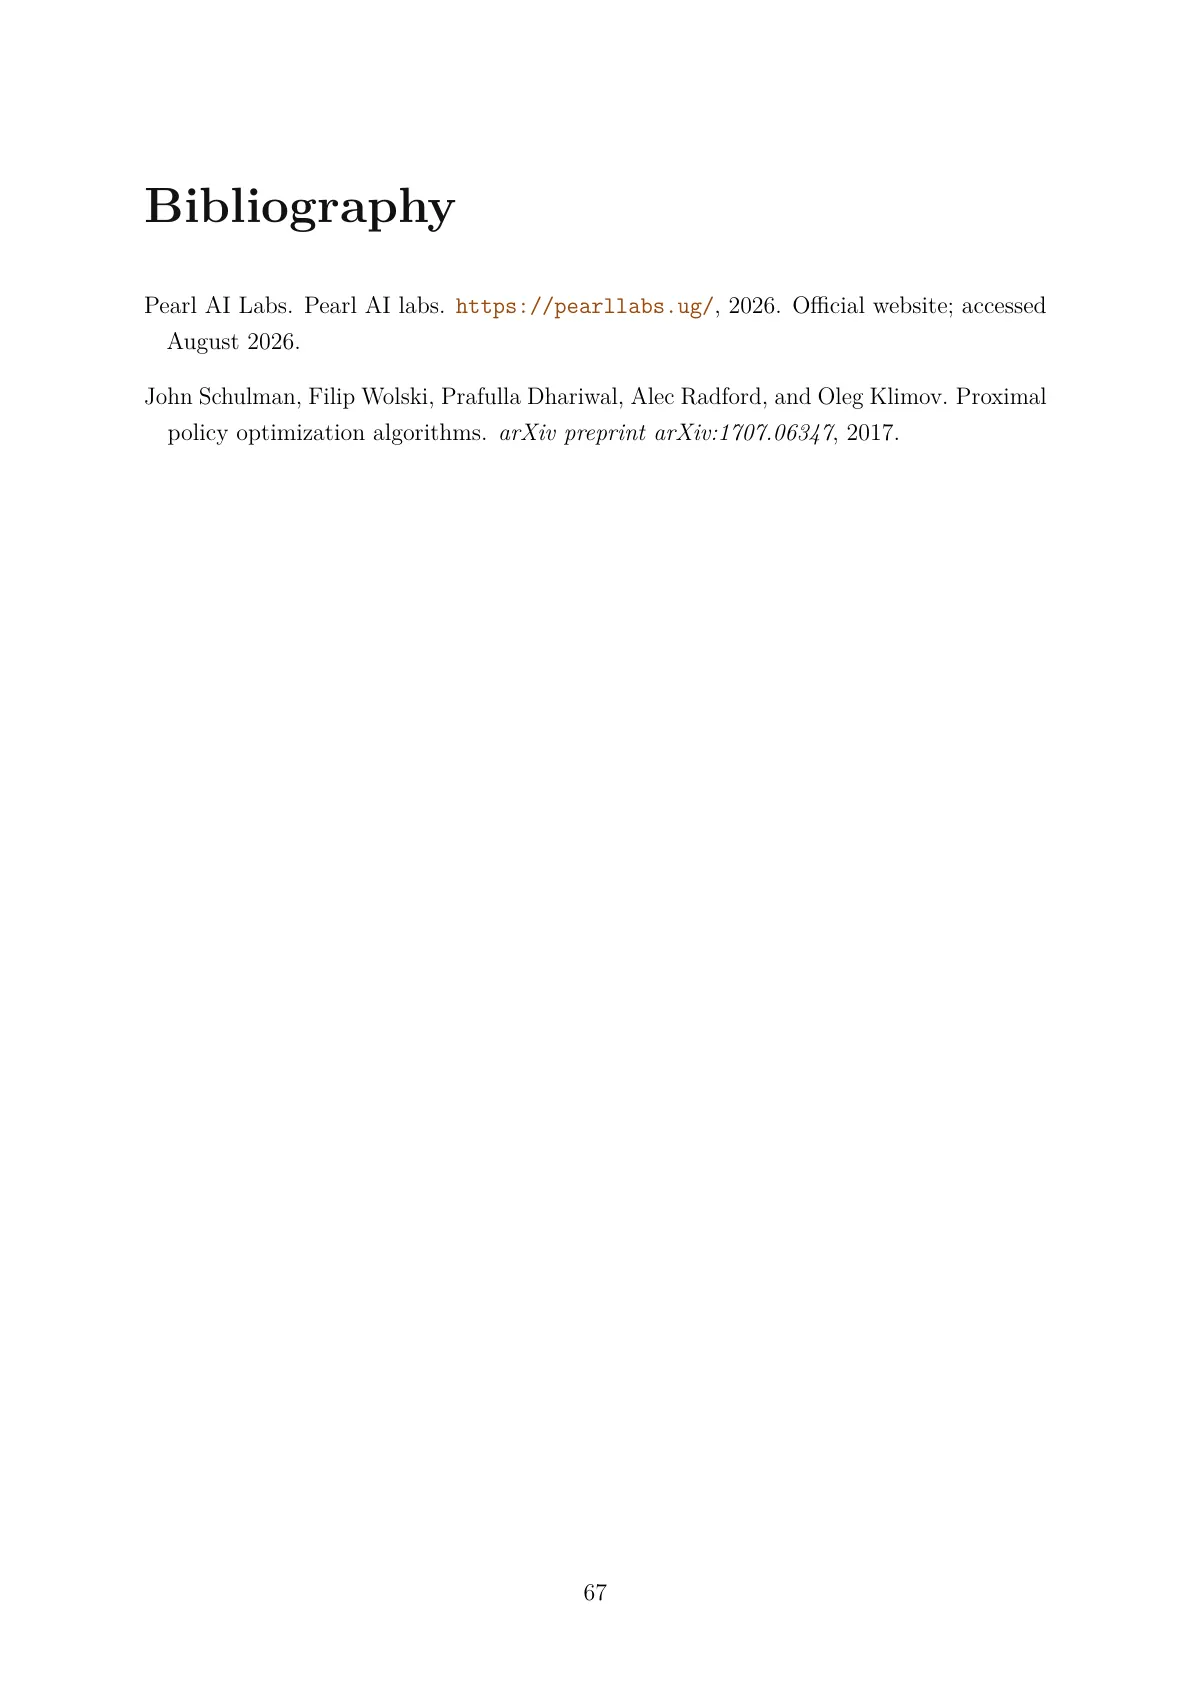
A low-cost autonomous rover built by seven Pearl AI Labs interns between 22 June and 7 August 2026. A navigation policy was trained with reinforcement learning (PPO) in a Unity digital twin of the vehicle, exported to ONNX and run on its NVIDIA Jetson Orin Nano, where every command — human or learned — passes through the same five safety guards. In the densest obstacle course it was trained on, the policy reached its target in about 80% of runs.
Group internship report · 79 pages